Get rrr-robotized with us
Subscribe and get monthly updates on what's happening on the robot baristas' lives. No spam. You have a robotic word!
By submitting this form you agree to our privacy policy.

BLOG


How to Choose the Right Robot Arm?

Choosing the right Robot Arm is not a matter of picking the largest payload or the fastest cycle time. The right choice depends on the task, workspace, accuracy needs, and conditions on the factory floor. A compact six-axis arm may reach around fixtures, while a SCARA robot may suit fast, repeatable assembly on a flat work surface. Small details matter: a cable snag, a heavy gripper, or a few centimeters of missed reach can change the whole setup.

Robotics expert Rodney Brooks wrote, “The world is its own best model.” His observation points to a practical rule: assess the real work environment, not just a product brochure. List the part’s weight, required reach, cycle time, mounting position, and expected precision. Then check payload with the tool and workpiece attached; rated capacity alone can mislead. Consider programming, maintenance, safety integration, and future product changes, too. A low purchase price can hide costly setup or downtime. It happens.

There is no universal winner. I would be cautious about treating any single specification as decisive, especially before testing the arm with the actual part and gripper. A short trial can reveal poor access, vibration, or awkward operator interaction that a table of specifications cannot. This guide explains how to compare robot types and key specifications, ask suppliers useful questions, and make a choice grounded in the job—not the sales pitch.
How to Choose the Right Robot Arm?

Identify the Main Types of Robot Arms

How to Choose the Right Robot Arm?

Identify the Main Types of Robot Arms

Robot arms are commonly grouped by how they move and the space they can reach. Cartesian arms travel along three straight axes, making their motion predictable and their work area rectangular. They suit tasks such as moving parts between fixed stations. SCARA arms combine horizontal reach with vertical movement, so they are often used for fast pick-and-place or assembly. Picture a component being lifted from a tray and pressed into a fixture. That repeatable path matters.

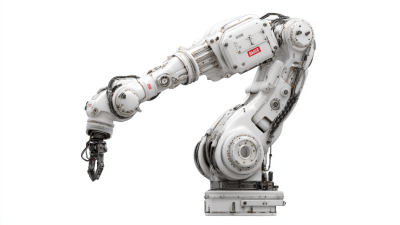
Articulated arms use rotating joints, much like a human shoulder and elbow. Their reach is flexible, which helps with welding, machine tending, and handling objects around obstacles. Delta arms use several linked arms above a work surface; their light structure supports rapid sorting of small items. Collaborative arms are designed to work near people, but safe operation still depends on the application, setup, and risk assessment.

No arm type fits every cell.

The categories overlap a little, and that can make comparison awkward. Look at the actual task: payload, reach, cycle time, mounting position, and required accuracy. A small sample layout can reveal clearance problems that a specification sheet misses.

Define the Task, Work Envelope, and Operating Conditions

How to Choose the Right Robot Arm?

Start with the task, not the catalog. List each operation, such as picking a 1.5-kilogram part from a tray and placing it inside a fixture. Include the gripper, cables, and any tool attached to the arm when calculating payload. Note the required cycle time and positioning accuracy, too. A fast arm may still be a poor fit if it cannot repeat the placement reliably.

Next, map the work envelope in three dimensions. Mark the farthest pick, highest shelf, and tightest approach, then check whether the arm can reach them without stretching near its limits. Leave room for the tool, guards, and nearby equipment. A common planning mistake is measuring only the part’s position; the approach path matters just as much. Check mounting options and cable movement before finalizing the layout.

Compare Payload, Reach, Speed, and Precision Requirements

A robot arm should be sized around the real task, not the heaviest number in a brochure. Calculate payload with the tool, workpiece, cables, and any changing grip included. A small extra margin helps, but an oversized arm can cost more and occupy valuable floor space. Check the load at full extension, too. The same object can strain the arm more when held farther from its base.

Reach is not simply the longest distance listed in a specification. Map the pickup and placement points, then check whether the arm can approach them without hitting fixtures, guards, or nearby equipment. Leave room for the gripper and for a safe path between positions. A paper sketch helps. It can still miss a bracket or cable route, so verify the layout on site.

Compare speed using the complete cycle, not just peak joint speed. Acceleration, pauses, tool changes, and settling time all affect output. Precision needs equal care: repeatability describes how consistently the arm returns to a point, while accuracy concerns how close that point is to the intended location. They are not interchangeable. A vision system or flexible part may add variation, even with a highly repeatable arm. Test representative parts under working conditions; early estimates are often a little too optimistic.

How to Choose the Right Robot Arm? - Compare Payload, Reach, Speed, and Precision Requirements

Application Typical Payload Typical Reach Typical TCP Speed Typical Repeatability Key Selection Considerations
Small-part assembly and electronics handling 0.5–3 kg 400–700 mm About 1–3 m/s About ±0.02–0.05 mm Prioritize repeatability, low vibration, and suitable end-effector fit. Include the gripper, cables, and other tooling in the payload calculation.
Machine tending and general material handling 3–12 kg 600–1,000 mm About 1.5–3 m/s About ±0.03–0.08 mm Check reach into the machine, clearance around doors and fixtures, cycle time, and the combined mass of the part and tooling.
Collaborative pick-and-place 3–16 kg 600–1,300 mm About 0.25–1.5 m/s, depending on the application and safety setup About ±0.02–0.10 mm Assess the complete collaborative application, including the tool, workpiece, speed, workspace, and risk assessment. Collaborative capability alone does not make every setup safe for shared operation.
Case packing and palletizing 10–30 kg 1,500–2,500 mm About 1.5–3 m/s About ±0.05–0.10 mm Allow for the full pallet pattern and approach paths. Evaluate wrist load, cycle rate, and whether the robot can reach all required pick and place points.
Heavy component handling 30–100 kg 2,000–3,200 mm About 1–2.5 m/s About ±0.05–0.15 mm Confirm payload at the required reach and wrist orientation, not just the rated maximum. Check mounting, braking, inertia limits, and foundation requirements.

Note: These are indicative ranges for common industrial robot applications, not guaranteed specifications for a particular robot. Actual payload, reach, speed, and repeatability vary by design and operating conditions. Repeatability describes the ability to return to a position; it is not the same as absolute positioning accuracy. Validate the required cycle time and workspace with the complete tool and workpiece.

Assess Safety, Controls, Integration, and Operating Costs

How to Choose the Right Robot Arm?

Assess Safety, Controls, Integration, and Operating Costs

A robot arm should fit the work cell, not just the product brochure. Start with the task’s reach, payload, speed, and cycle time. Then assess hazards around the arm, gripper, and moving workpieces. A risk assessment can identify where guarding, scanners, or reduced-speed modes are needed. Leave room for maintenance access; a cramped cell makes routine checks harder.

Controls shape how quickly operators can run and troubleshoot the system. Check whether the interface makes it easy to adjust a position, identify a fault, or stop motion safely. During integration, confirm the arm can communicate with existing conveyors, sensors, and safety equipment. Test the full sequence with real parts, not only a simulation. A glossy demo may hide awkward recovery steps.

Operating costs include more than the purchase price. Estimate energy use, tooling, service, spare parts, and the labor needed for changeovers. On a packaging line, a small gripper adjustment can affect every shift’s output. Even a careful estimate can miss downtime from unfamiliar controls. That deserves a second look. Compare costs over the expected service life, and revisit the estimate when production assumptions change.

Match Robot Arm Specifications to the Application

A robot arm should fit the task, not just the budget. Start with the part’s weight, including grippers, cables, and any product held during motion. Then measure the farthest point the tool must reach. A heavy load at full extension can exceed a model’s practical capacity, even when the catalog payload looks sufficient.

Match repeatability and speed to the process. A packaging line may need fast, consistent placement; machine tending may need reliable reach through a narrow opening. The International Federation of Robotics reported 541,302 industrial robot installations worldwide in 2023, in World Robotics 2024. That scale reflects varied applications, not one universal specification. Check wrist torque, mounting position, duty cycle, and the workcell’s dust, moisture, and temperature. Small details matter.

Test the actual tool path with a representative part. Observe the arm at its longest reach, with the intended gripper attached. Confirm that cycle time leaves room for acceleration, settling, and safe interaction with nearby equipment. A spreadsheet can miss cable drag or awkward access. It happens. Also verify that the controller, sensors, and safety setup fit the cell; these needs can change installation effort and throughput. Leave a little capacity for product variation, but avoid buying far more reach or payload than the job uses. Over-sizing is easy to justify—and not always wise.

How to Choose the Right Robot Arm?

Match robot arm specifications to the application

The ranges shown are indicative planning estimates, not universal limits. Include the gripper, tooling, cables, and workpiece when calculating payload. Then check reach, wrist load, speed, accuracy, and the working environment against the application and the robot’s manufacturer specifications.